Module with data types and subroutines for coupled modal analysis. More...
Data Types | |
| type | structsensorgradtype |
| Data type representing a control input gradient. More... | |
| type | forcecontrolgradtype |
| Data type representing a control output gradient. More... | |
| type | controlstructtype |
| Data type representing the control-system/structure coupling. More... | |
| interface | writeobject |
| Standard routine for writing an object to file. More... | |
Functions/Subroutines | |
| subroutine | writecontrolstructtype (pCS, io, complexity) |
| Standard routine for writing an object to io. More... | |
| subroutine | initiatecontrolstruct (pCS, inputs, triads, joints, forces, numVreg, numNod, ierr) |
| Initializes the control struct data type. More... | |
| subroutine | getctrlparamswithstructsensors (ctrlParams, numStructCtrlParams, ctrlParamsWithStructSensors) |
| Finds all control input parameters coupled to structural DOFs. More... | |
| subroutine | getctrloutforces (forces, numCtrlOutForces, ctrlOutForces) |
| Finds all control out forces. More... | |
| subroutine | buildstructcontroljacobi (pCS, ctrl, sys, msim, ierr) |
| Computes the gradient matrices of forces w.r.t. controller inputs. More... | |
| subroutine | estimatecontrollerproperties01 (sys, ctrl, msim, whichVregIn, whichVregOut, ctrlProps, ierr) |
| Estimates the controller gradient properties by perturbation. More... | |
| subroutine | estimatecontrollerproperties02 (sys, ctrl, msim, whichVregIn, whichVregOut, ctrlProps, ierr) |
| subroutine | estimatecontrollerproperties03 (sys, ctrl, msim, whichVregIn, whichVregOut, ctrlProps, ierr) |
| subroutine | estimatecontrollerproperties04 (sys, ctrl, msim, whichVregIn, whichVregOut, nStep, ctrlProps, ierr) |
| subroutine | estimatecontrollerproperties500 (sys, ctrl, msim, whichVregIn, whichVregOut, ctrlProps, ierr) |
| Perturbation method without initial perturbation. More... | |
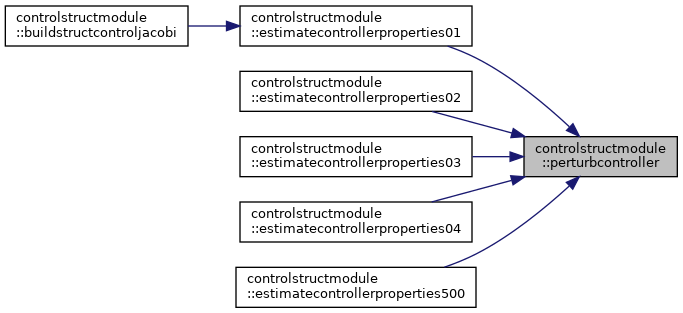
| subroutine | perturbcontroller (sys, ctrl, msim, iPert, dt, dy, numVregOut, whichVregOut, uy, ierr) |
| Perturbs one of the inputs of the control system. More... | |
| subroutine | deallocatectrlcopy (ctrl) |
| Deallocates a control system copy. More... | |
Detailed Description
Module with data types and subroutines for coupled modal analysis.
This module contains some data types and associated subroutines for conducting coupled modal analysis of mechanim models with control systems.
Function/Subroutine Documentation
◆ buildstructcontroljacobi()
| subroutine controlstructmodule::buildstructcontroljacobi | ( | type(controlstructtype), intent(inout) | pCS, |
| type(controltype), intent(in) | ctrl, | ||
| type(systemtype), intent(inout) | sys, | ||
| integer, dimension(:), intent(in) | msim, | ||
| integer, intent(out) | ierr | ||
| ) |
Computes the gradient matrices of forces w.r.t. controller inputs.
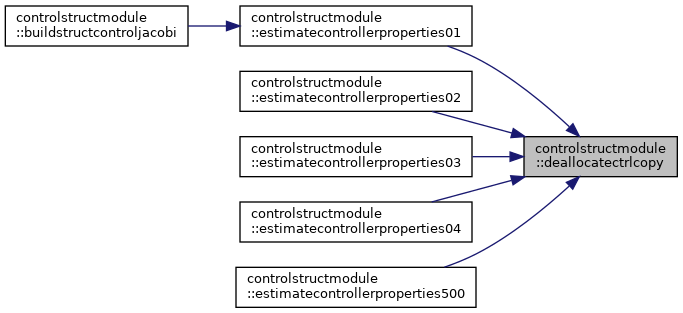
◆ deallocatectrlcopy()
| subroutine controlstructmodule::deallocatectrlcopy | ( | type(controltype), pointer | ctrl | ) |
Deallocates a control system copy.
- Parameters
-
ctrl Pointer to controltypemodule::controltype object to deallocate.
- Date
- 19 Jan 2024
◆ estimatecontrollerproperties01()
| subroutine controlstructmodule::estimatecontrollerproperties01 | ( | type(systemtype), intent(inout) | sys, |
| type(controltype), intent(in) | ctrl, | ||
| integer, dimension(:), intent(in) | msim, | ||
| integer, dimension(:), intent(in) | whichVregIn, | ||
| integer, dimension(:), intent(in) | whichVregOut, | ||
| real(dp), dimension(:,:,:), intent(out) | ctrlProps, | ||
| integer, intent(out) | ierr | ||
| ) |
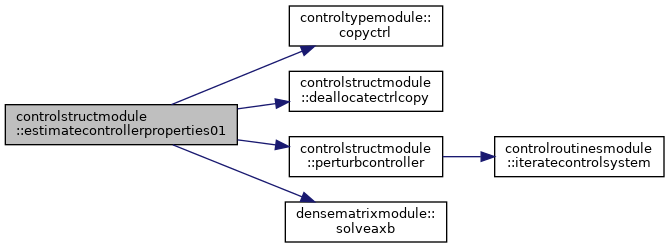
Estimates the controller gradient properties by perturbation.
- Parameters
-
sys System level model data ctrl Control system data [in] msim Matrix of simulation parameters [in] whichVregIn Which vreg inputs to perturb [in] whichVregout Which vreg outputs to read variation from [out] ctrlProps 3D table for storing controller properties (no. of outputs, no. of controller properties, no. of inputs) - ctrlProps(:,1,:) = Q
- ctrlProps(:,2,:) = K
- ctrlProps(:,3,:) = C
- ctrlProps(:,4,:) = M
[out] ierr Error flag
We use a perturbation method, simular to the Matrix Stiffness Method / (Virtual) Displacement Method / Unit Load Method to find the equivalent mechanical properties of the controller. These controller properties will be added to existing matrices when conducting modal/eigenvalue analysis.
In this routine, the controller is limited to be of type PID. The equation for the system is:
M*x'' + C*x' + K*x + Q*int(x)dt = F
or
M*(d2x/dt2) + C*(dx/dt) + K*x + Q*int(x)dt = F
where M is the mass, C is the damping, K is the stiffness, and Q is the steady state error elimination.
Controller input = y, controller output = u.
The values of interest are:
- du/dy: The change du in output from controller with respect to the change dy in input to controller. du/dy = proportional gain, Kp.
- du/(int(dy)dt): The change du in output from controller with respect to the change int(dy)dt in input to controller. du/(int(dy)dt) = integral gain, Ki.
- du/(dy/dt): The change du in output from controller with respect to the change dy/dt in input to controller. du/(dy/dt) = derivative gain, Kd.
Working order:
- Do an initial perturbation on the controller with dy = 0 and dt ≠ 0. This is to insure dy/dt = 0.
- Get the initial values y0 and u0 for the controller.
- Establish dy(j) and dt(j). j = number of perturbations. For a PID-controller: j = 1...3.
- Calculate d(int(dy(j))dt) and d(dy/dt).
- Calculate y(j) and t(j).
- Iterate the controller with these new values for the input y(j) and time t(j) and save the reaction from the controller u(j) due to the change in the input.
- Calculate du(j) based on u0 and u(j).
- Calculate Kp, Ki and Kd.
- Based on sensor type (position, velocity or acceleration), calculate Q, K, C and M.
- Date
- 25 Nov 2010
◆ estimatecontrollerproperties02()
| subroutine controlstructmodule::estimatecontrollerproperties02 | ( | type(systemtype), intent(inout) | sys, |
| type(controltype), intent(in) | ctrl, | ||
| integer, dimension(:), intent(in) | msim, | ||
| integer, dimension(:), intent(in) | whichVregIn, | ||
| integer, dimension(:), intent(in) | whichVregOut, | ||
| real(dp), dimension(:,:,:), intent(out) | ctrlProps, | ||
| integer, intent(inout) | ierr | ||
| ) |
◆ estimatecontrollerproperties03()
| subroutine controlstructmodule::estimatecontrollerproperties03 | ( | type(systemtype), intent(inout) | sys, |
| type(controltype), intent(in) | ctrl, | ||
| integer, dimension(:), intent(in) | msim, | ||
| integer, dimension(:), intent(in) | whichVregIn, | ||
| integer, dimension(:), intent(in) | whichVregOut, | ||
| real(dp), dimension(:,:,:), intent(out) | ctrlProps, | ||
| integer, intent(inout) | ierr | ||
| ) |
◆ estimatecontrollerproperties04()
| subroutine controlstructmodule::estimatecontrollerproperties04 | ( | type(systemtype), intent(inout) | sys, |
| type(controltype), intent(in) | ctrl, | ||
| integer, dimension(:), intent(in) | msim, | ||
| integer, dimension(:), intent(in) | whichVregIn, | ||
| integer, dimension(:), intent(in) | whichVregOut, | ||
| integer, intent(in) | nStep, | ||
| real(dp), dimension(:,:,:), intent(out) | ctrlProps, | ||
| integer, intent(inout) | ierr | ||
| ) |
◆ estimatecontrollerproperties500()
| subroutine controlstructmodule::estimatecontrollerproperties500 | ( | type(systemtype), intent(inout) | sys, |
| type(controltype), intent(in) | ctrl, | ||
| integer, dimension(:), intent(in) | msim, | ||
| integer, dimension(:), intent(in) | whichVregIn, | ||
| integer, dimension(:), intent(in) | whichVregOut, | ||
| real(dp), dimension(:,:,:), intent(out) | ctrlProps, | ||
| integer, intent(inout) | ierr | ||
| ) |
Perturbation method without initial perturbation.
Perturbation w.r.t. a single integral. nPerturb = 1 in this subroutine, therefore no loop necessary.
- Date
- 7 July 2010
◆ getctrloutforces()
| subroutine controlstructmodule::getctrloutforces | ( | type(forcetype), dimension(:), intent(in), target | forces, |
| integer, intent(out) | numCtrlOutForces, | ||
| integer, dimension(:), intent(out), pointer | ctrlOutForces | ||
| ) |
Finds all control out forces.
◆ getctrlparamswithstructsensors()
| subroutine controlstructmodule::getctrlparamswithstructsensors | ( | type(ctrlprm), dimension(:), intent(in), target | ctrlParams, |
| integer, intent(out) | numStructCtrlParams, | ||
| integer, dimension(:), intent(out), pointer | ctrlParamsWithStructSensors | ||
| ) |
Finds all control input parameters coupled to structural DOFs.
◆ initiatecontrolstruct()
| subroutine controlstructmodule::initiatecontrolstruct | ( | type(controlstructtype), intent(out) | pCS, |
| type(ctrlprm), dimension(:), intent(in), target | inputs, | ||
| type(triadtype), dimension(:), intent(in), target | triads, | ||
| type(masterslavejointtype), dimension(:), intent(in), target | joints, | ||
| type(forcetype), dimension(:), intent(in), target | forces, | ||
| integer, intent(in) | numVreg, | ||
| integer, intent(in) | numNod, | ||
| integer, intent(out) | ierr | ||
| ) |
Initializes the control struct data type.
◆ perturbcontroller()
| subroutine controlstructmodule::perturbcontroller | ( | type(systemtype), intent(inout) | sys, |
| type(controltype), intent(inout) | ctrl, | ||
| integer, dimension(:), intent(in) | msim, | ||
| integer, intent(in) | iPert, | ||
| real(dp), intent(in) | dt, | ||
| real(dp), intent(in) | dy, | ||
| integer, intent(in) | numVregOut, | ||
| integer, dimension(:), intent(in) | whichVregOut, | ||
| real(dp), dimension(:), intent(out) | uy, | ||
| integer, intent(out) | ierr | ||
| ) |
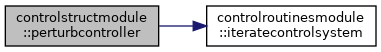
Perturbs one of the inputs of the control system.
- Parameters
-
sys System level model data ctrl Control system data [in] msim Matrix of simulation parameters [in] iPert Which input to perturb [in] dt Incremental time step [in] dy Incremental step for use in du/dy [in] numVregOut Number of outputs from the controller to read [in] whichVregOut Which outputs from the controller to read [out] uy Perturbed output from controller, u(y) = u(y0+dy) [out] ierr Error flag
This subroutine perturbs one of the control inputs and calculates the reaction in all of the control outputs.
Working order: 1) Change the input y for the controller from y0 to y = y0+dy, where dy is a small number. Change the time from t0 to t = t0+dt, where dt is a small number. 2) Run this new input through the controller to get the reaction (output) u(y) from the controller due to the change in the input.
- Date
- 18 Sept 2009
◆ writecontrolstructtype()
| subroutine controlstructmodule::writecontrolstructtype | ( | type(controlstructtype), intent(in) | pCS, |
| integer, intent(in) | io, | ||
| integer, intent(in) | complexity | ||
| ) |
Standard routine for writing an object to io.
- Parameters
-
[in] pCS Data for coupled control system and structure modal analysis [in] io File unit number to write to [in] complexity Indicates the amount of print
- Date
- 19 Feb 2024
